Revo 3 Robotic Hand Details
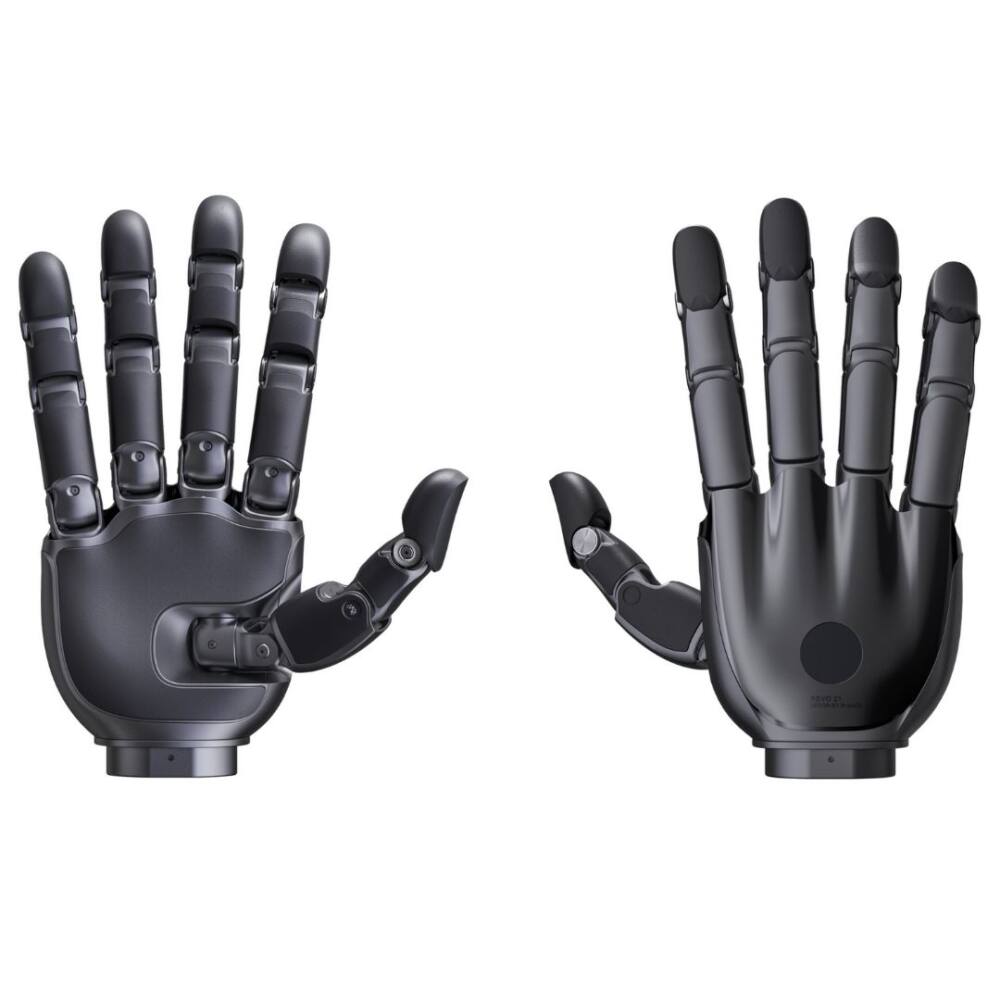
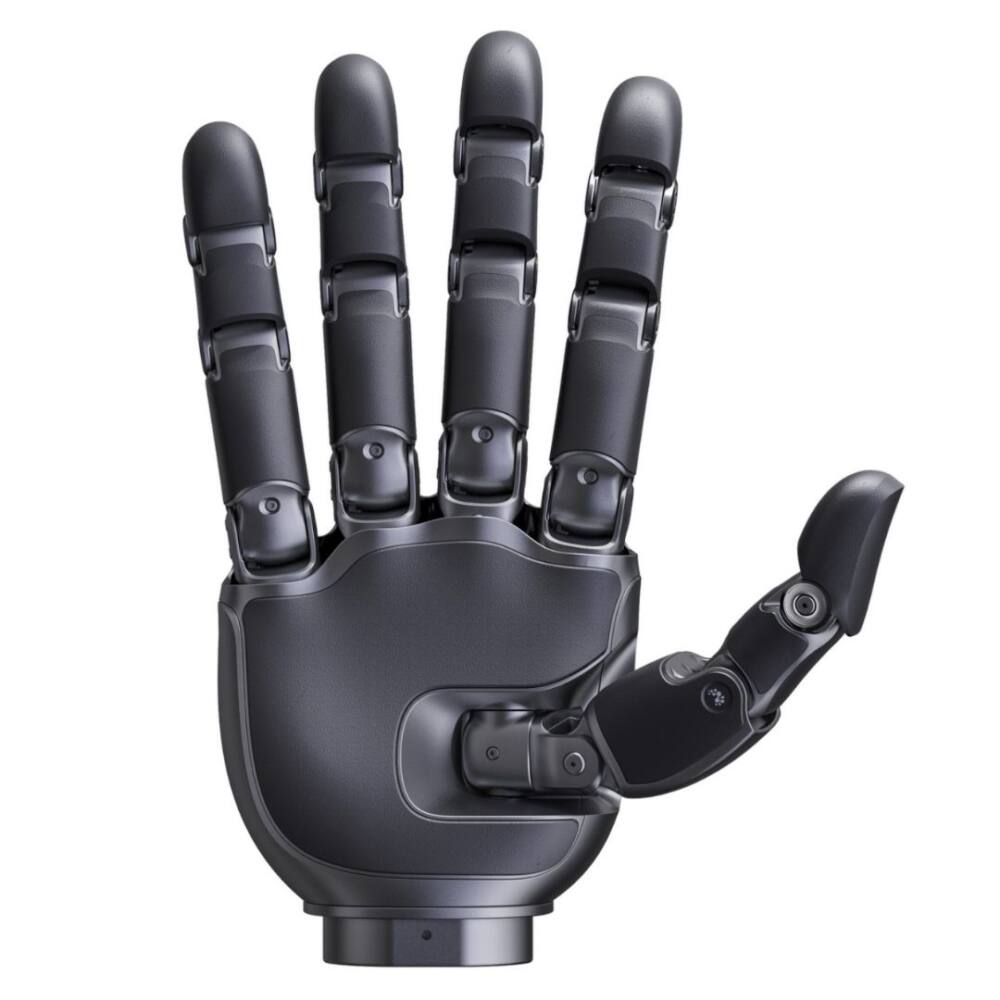
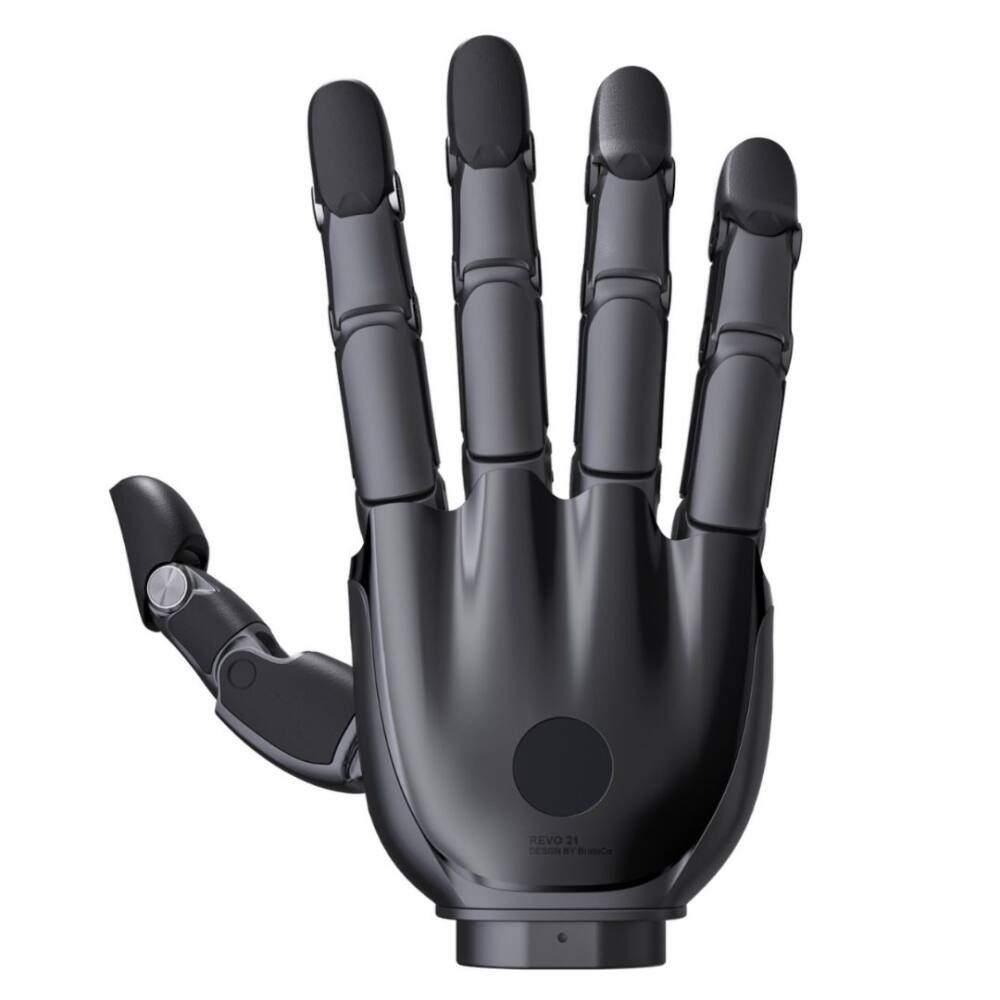
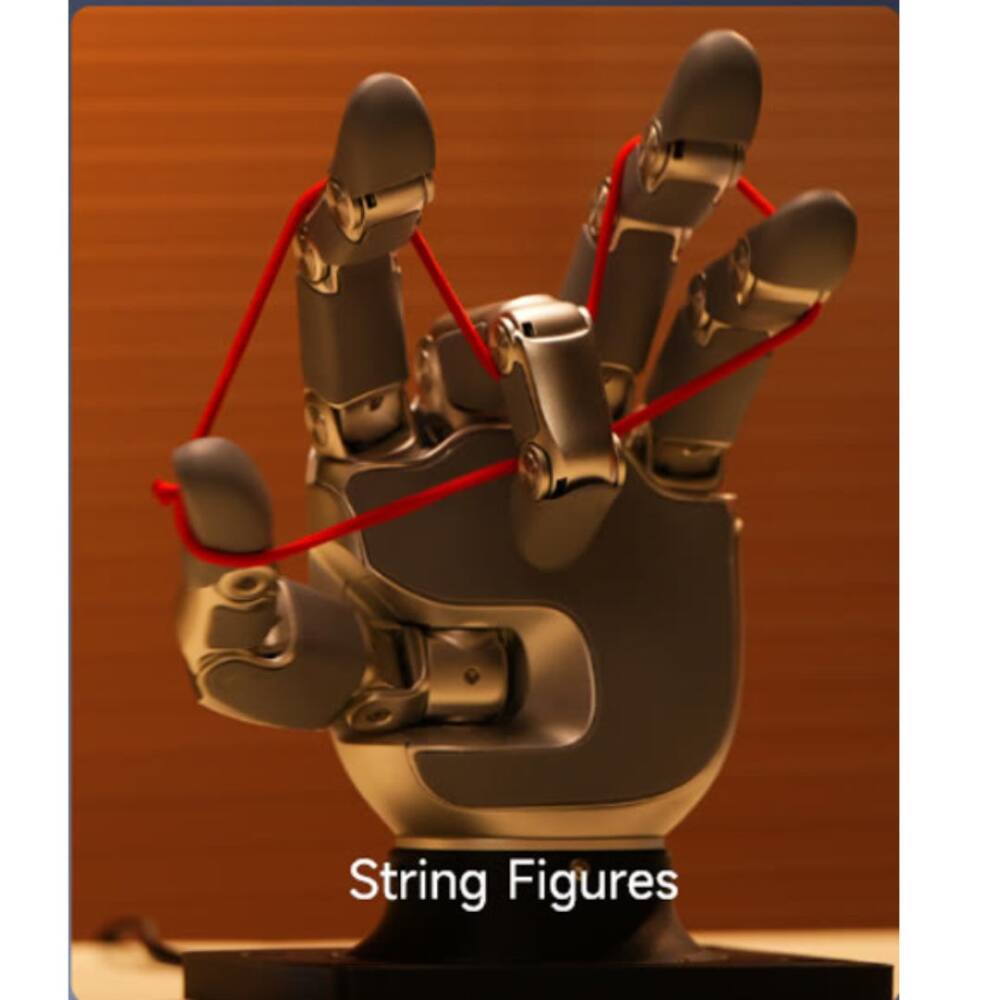
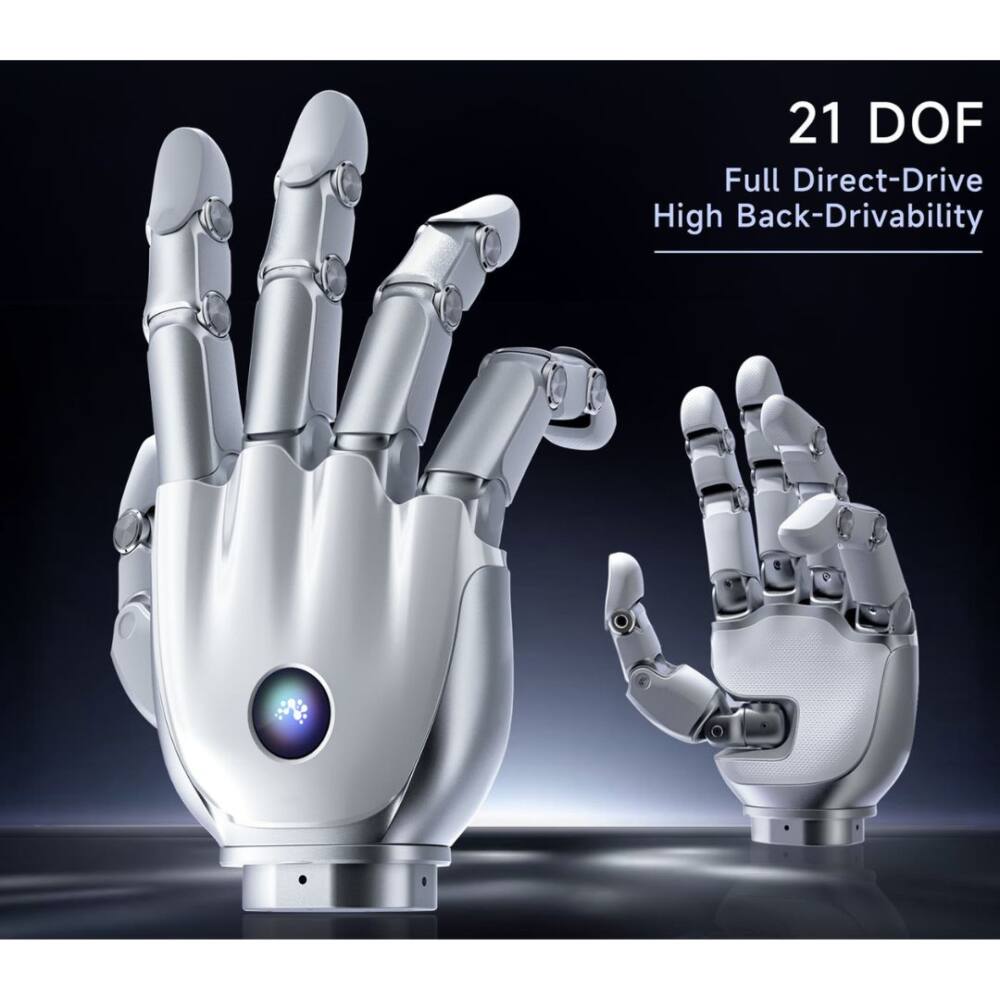
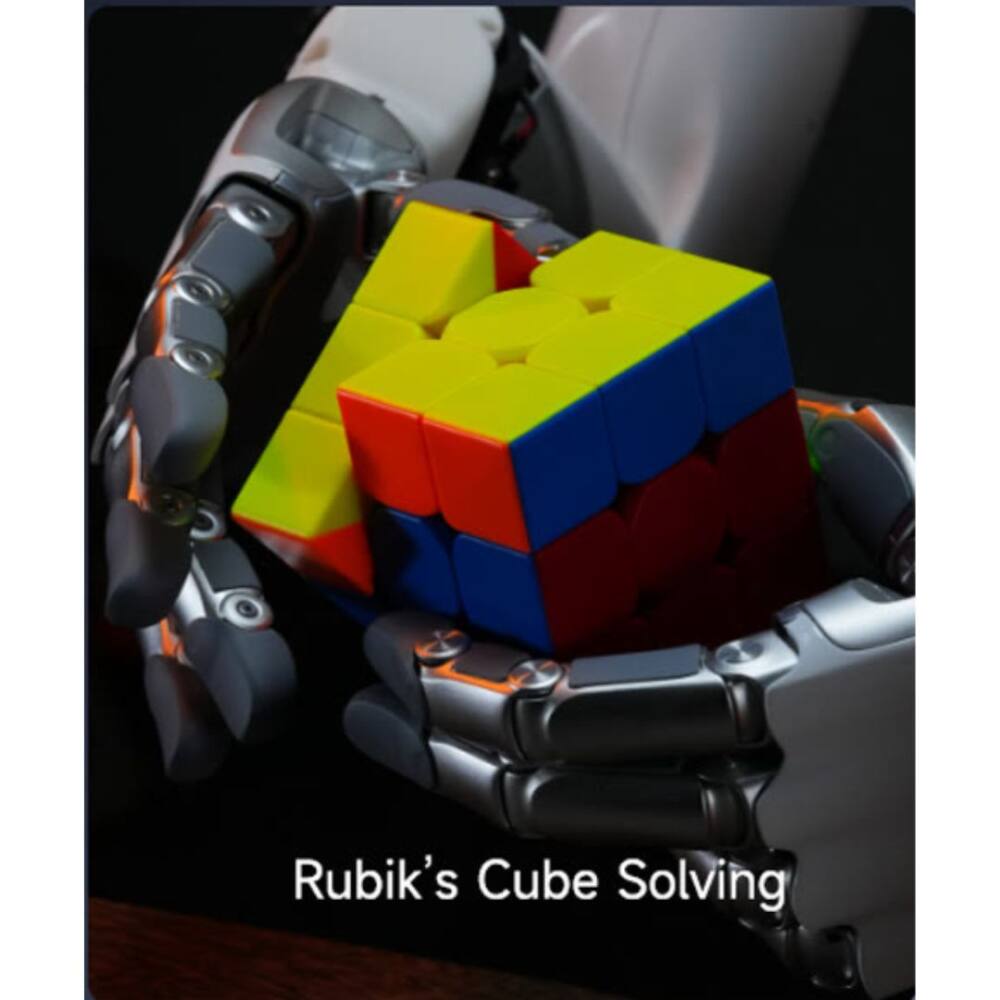
Revo 3 features 21 active degrees of freedom, with four DOF per finger and five in the thumb. Its integrated direct-drive joint modules are fully back-drivable and combine the torque motor, reducer, driver, and dual encoders inside the hand. The platform delivers 0.1° repeatability, up to 70 N grip force, 20 N fingertip pinch force, and a 20 kg whole-hand load, with motion covering all 33 functional human grasps.
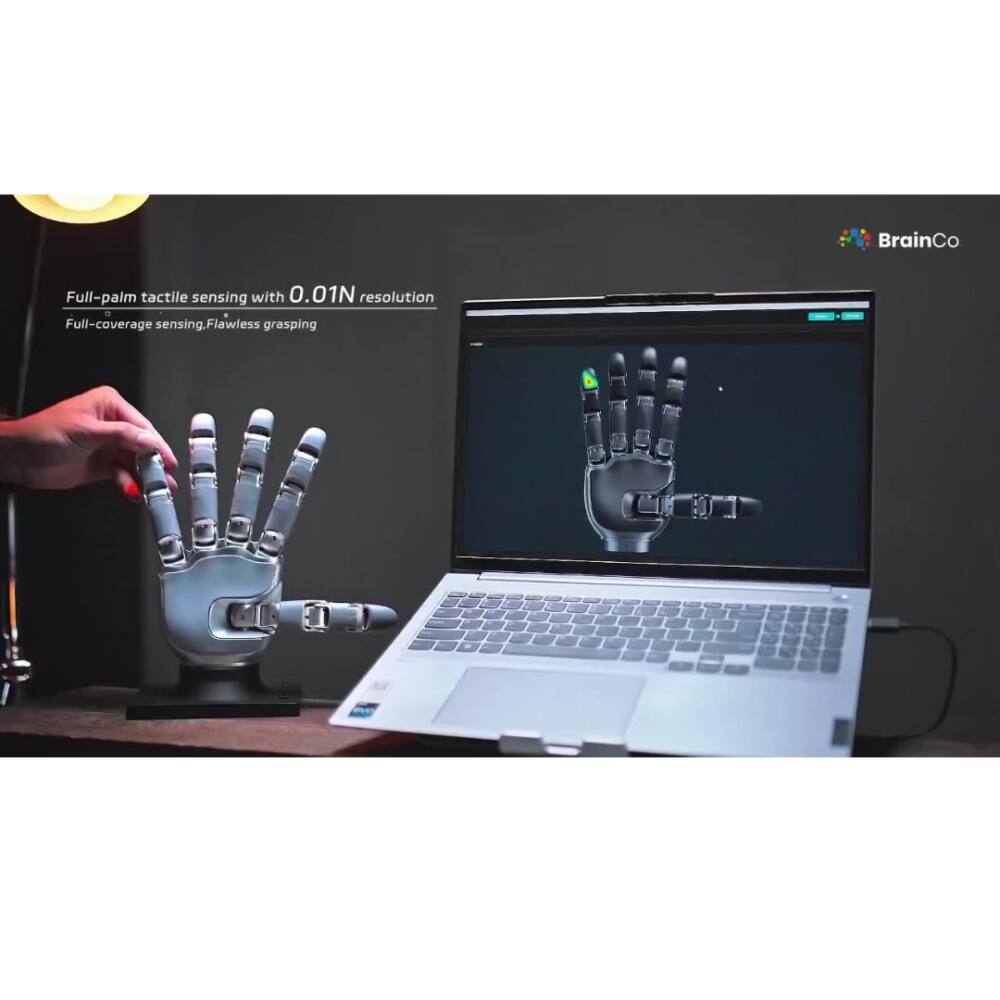
Advanced sensing configurations add a 400+ point full-palm tactile array at 100 Hz, with options for visuo-tactile fingertips capable of detecting deformation down to 130 µm. Control modes include position, MIT force-position, admittance, and zero-torque control.
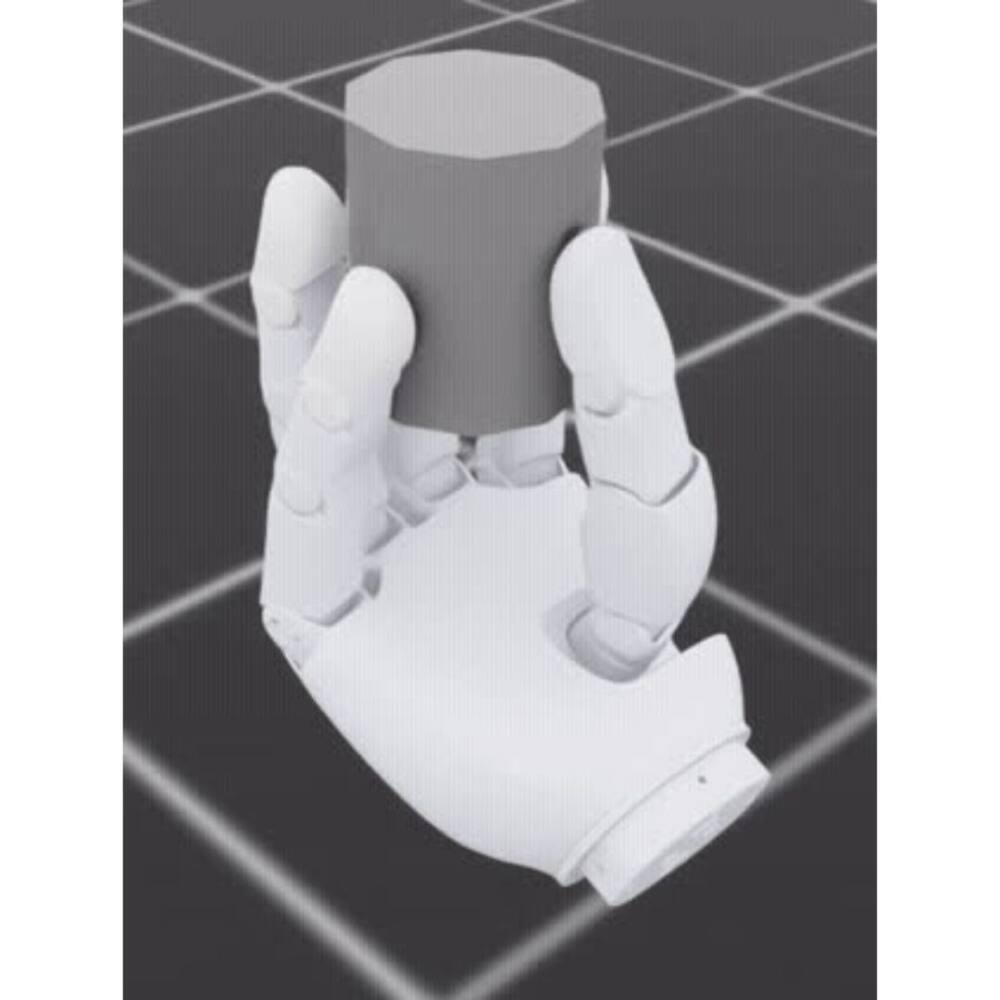
For development, Revo 3 uses an open-source embodied-AI stack with sim-to-real support for NVIDIA Omniverse / Isaac, MuJoCo, ManiSkill, ROS, Gazebo, and Genesis AI.
For physical integration, the current specification lists a 24–80 V supply range and RS-485 as the shipping interface, with CAN FD and EtherCAT in development. Revo 3 also includes a VBTS expansion interface for tactile and sensor data.
Get a quote for Revo 3 Robotic Hand
Click "Add To My Products" below to add this product to your request for information. Feel free to keep searching our catalog and add more products to your inquiry list. When you're done, click the "My Products" button at the top right of your screen to complete your request.